Dyna-2: General Purpose Physical Agents with Hour-Long Autonomy — Jason Ma, Dyna Robotics
Watch along AIE NYC and join us at AIE CODE in SF next month!
This episode includes a live demo of the Taku robot that is best enjoyed on YouTube.
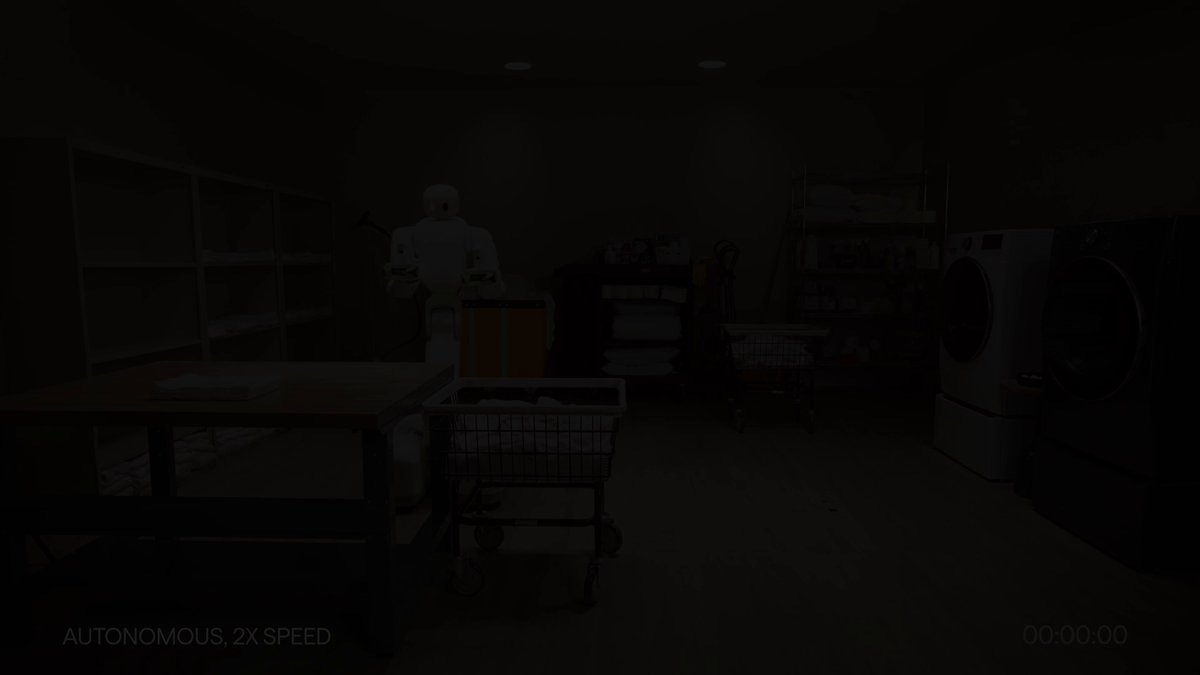
Last month, Dyna made waves by announcing Dyna-2, a world-action model pre-trained on one million hours of human video, claiming several new scaling laws on human data across four orders of magnitude. They have now followed up the model with a physical robot agent, Dyna-2.1, that has to be seen to be believed:
In his talk at AIE this year, Jason talked about how the real challenge for robotics in the real world is reliable, long-horizon autonomy, and how Dyna got its models to a 99.4% success rate folding restaurant napkins for 24 hours straight, including recovering after it pulled over the whole stack.
From training a world-action model on over one million hours of human video to deploying robots that fold thousands of napkins daily at Din Tai Fung, Dyna Robotics is pushing physical AI beyond impressive demos and into real-world production. In this episode, Dyna Robotics co-founder and Chief Scientist Jason Ma joins swyx on-site to unpack how robots can learn new tasks from as little as 45 minutes of demonstrations, why predicting the future of the physical world may be the key to general-purpose robotics, and what it actually takes to build robots that work reliably for real customers.
We go deep on Dyna-2, Dyna’s million-hour world-action model that combines future video prediction with robot actions, the scaling laws behind human-to-robot transfer, diffusion transformers and flow matching, and why synthetic environments and self-generated training data could unlock the next wave of robotics progress. Jason also explains why Dyna builds its own hardware instead of relying on off-the-shelf humanoids, how agentic harnesses enable robots to execute hour-long workflows, why dexterous hands and missing sensory data remain major bottlenecks, and what separates real commercial deployments from the graveyard of robotics startups. We also cover world-action models versus vision-language-action models, GPT-6 and coding agents in robotics, and Jason’s journey from AlphaGo and Penn to NVIDIA, Google DeepMind, and founding Dyna.
We discuss:
* Why Dyna-2 was trained on over one million hours of human video
* World-action models: predicting future video to guide physical robot actions
* Diffusion transformers, flow matching, and real-time robotic control
* How robots learn new tasks with as little as 45 minutes of demonstrations
* Why robotics has no equivalent of the internet and data remains its biggest scaling challenge
* Human egocentric video, robot demonstrations, and cross-embodiment transfer
* Synthetic environments, simulation, and models that generate their own training data
* Why robots need on-device inference, model distillation, and custom hardware
* Why Dyna chose wheeled semi-humanoids instead of traditional bipedal robots
* The hardware bottleneck: why dexterous robot hands still overheat
* Best Western, Din Tai Fung, and the difference between robotics pilots and scaled deployments
* The Bitter Lesson of Robotics: scaling data instead of engineering specialized solutions
* Agentic harnesses and robots executing multi-step, hour-long physical workflows
* GPT-6, coding agents, and AI-generated simulation environments for robotics research
* World-action models vs. VLAs, and why vision alone may not be enough
* Jason’s journey through AlphaGo, Penn, NVIDIA, Google DeepMind, and the Eureka project
* Dyna’s research culture, deployment-first philosophy, and vision for millions of robots
Jason Ma
* LinkedIn: https://www.linkedin.com/in/jason-ma-742224a2/
* X: https://x.com/JasonMa2020
Dyna Robotics
* Website: https://www.dyna.co/
* X: https://x.com/DynaRobotics
Timestamps
00:00:00 Introduction and Dyna-2’s World-Action Model
00:03:08 Diffusion Transformers, Flow Matching, and Generalist Robots
00:08:19 The Robotics Data Bottleneck
00:13:50 Synthetic Data and Self-Improving World Models
00:16:51 Real-Time Inference and Model Distillation
00:19:45 Full-Stack Robotics: Hardware and Supply Chains
00:25:02 Why Dyna Built a Wheeled Semi-Humanoid
00:29:35 Teaching Robots New Tasks and Evaluating Performance
00:31:59 Autonomous Workflows and Hardware Limitations
00:36:06 Real-World Deployments at Best Western and Din Tai Fung
00:41:07 The Bitter Lesson of Robotics
00:46:13 Agentic Harnesses for Physical AI
00:49:07 GPT-6, Coding Agents, and AI-Native Robotics
00:52:02 World-Action Models vs. VLAs
00:59:17 From AlphaGo to Founding Dyna Robotics
01:04:20 Dyna’s Research Culture and the Future of Robotics
Transcript
Introduction: Jason Ma and Dyna Robotics
Swyx [00:00:00]: All right, we’re here on site with Jason Ma, the co-founder, chief scientist of Dyna Robotics. Thanks for having us in your office.
Jason Ma [00:00:06]: Of course. Thank you for coming.
Vibhu [00:00:07]: It’s been a blast. We got to see—you’ll see plenty of B-roll—drinks being pulled, a lot of evals, robots with knives for the first time. So under the hood of all this you have a world action model. What is that?
Dyna-2: A World Action Model That Predicts the Future
Jason Ma [00:00:22]: So last month, we released our world action model called Dyna-2. So it’s the first world action model trained on more than one million hours of data. So going back to your question first, world action model is a model that’s able to predict the future video, the future state of the world, so hence the name world model. But in addition, you can also use that future generation to also produce actions robots can execute in the physical world to control the robot. So why do we do that? It’s a very powerful architecture, because if you think about how humans act in the physical world, in our brain, we are implicitly thinking about how the world will evolve based on our actions. So now we have a model architecture that’s able to do that to g
You May Also Like

Artificial Intelligence Masterclass
AI Masterclass

Mark Tilbury
Mark Tilbury Fan

The Good Tech Companies
HackerNoon

Jack Hopkins
Jack Hopkins

How I AI
Brooke Gramer

Engadget News + Next
Engadget
Syntax - Tasty Web Development Treats
Wes Bos & Scott Tolinski - Full Stack JavaScript Web Developers
Bankless
Bankless

a16z Show
Andreessen Horowitz

AI Fire Daily
AIFire.co
Artificial Intelligence Masterclass
AI Masterclass
Mark Tilbury
Mark Tilbury Fan
The Good Tech Companies
HackerNoon
Jack Hopkins
Jack Hopkins
How I AI
Brooke Gramer
Engadget News + Next
Engadget
Syntax - Tasty Web Development Treats
Wes Bos & Scott Tolinski - Full Stack JavaScript Web Developers
Bankless
Bankless
a16z Show
Andreessen Horowitz
AI Fire Daily
AIFire.co
Community discussion