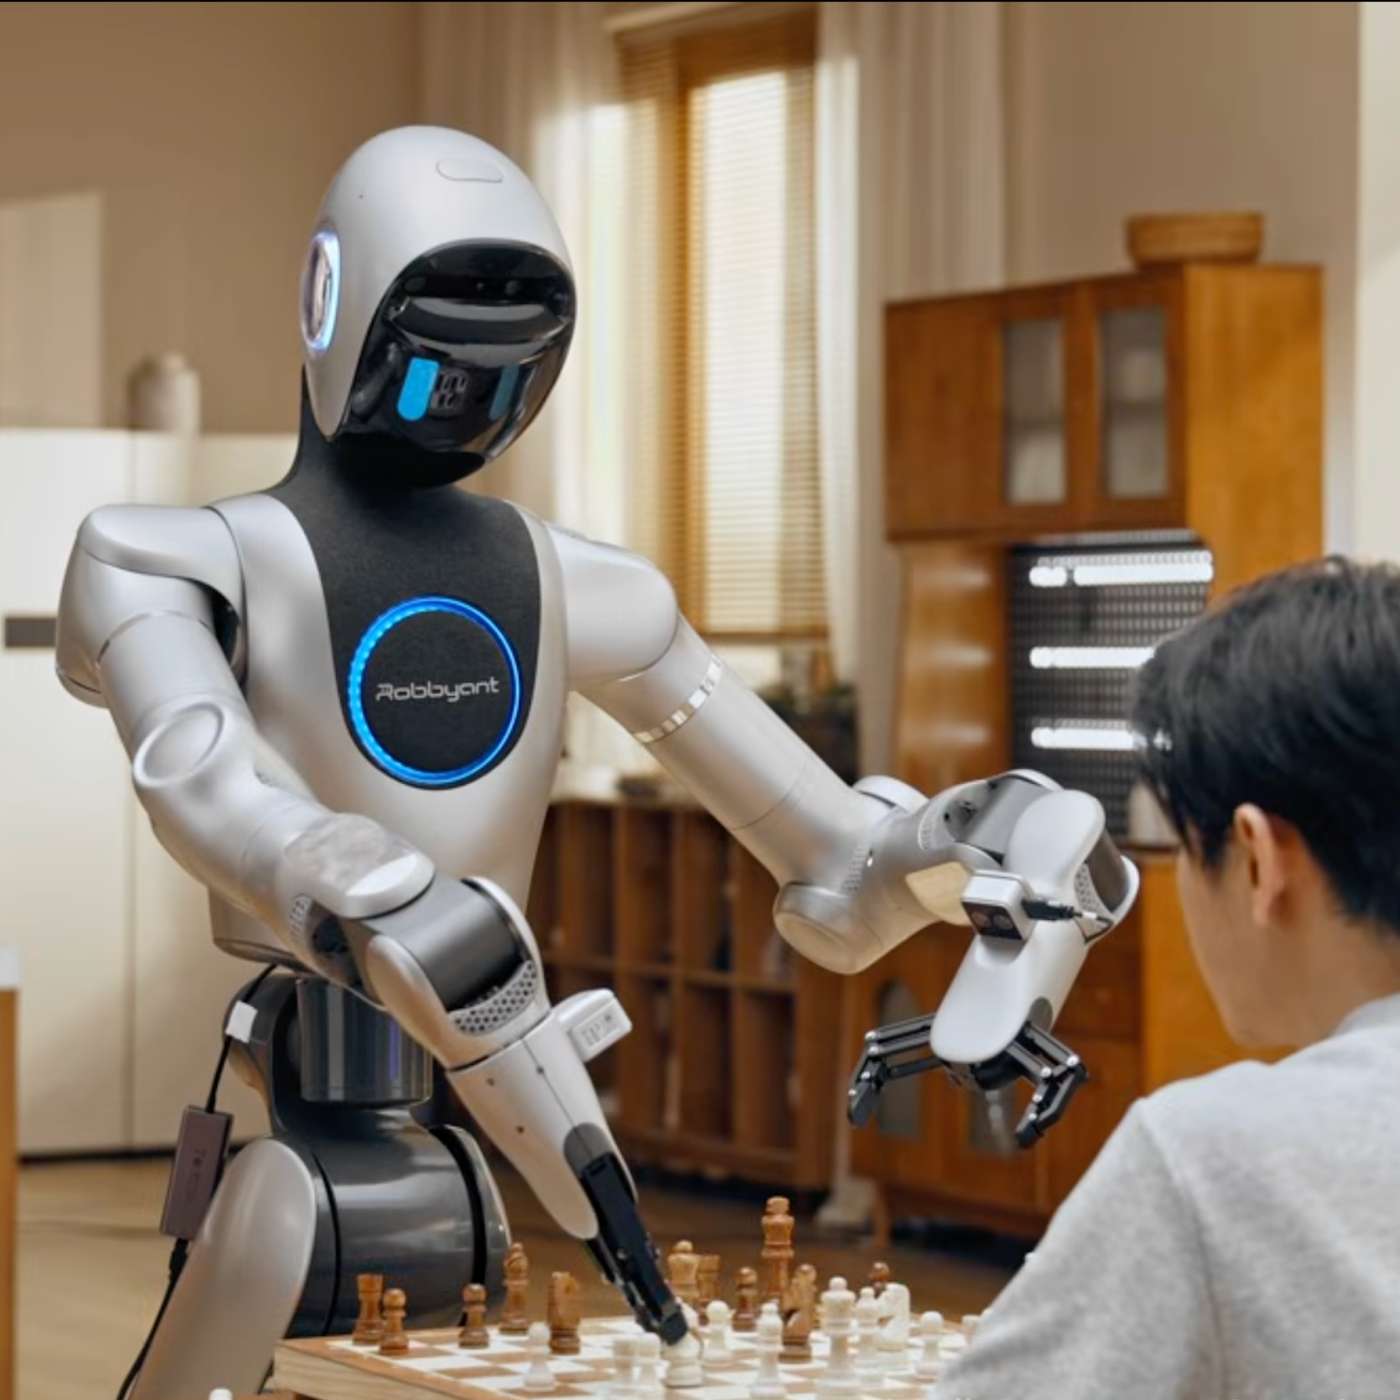
Why Robots Need Intelligence Built for the Physical World
This story was originally published on HackerNoon at: https://hackernoon.com/why-robots-need-intelligence-built-for-the-physical-world.
Discover how Robbyant’s LingBot 2.0 connects perception, world modeling, and physical action to build embodied intelligence across different robot bodies.
Check more stories related to undefined at: https://hackernoon.com/c/undefined. You can also check exclusive content about #physical-ai-systems, #cross-embodiment-ai, #multi-robot-ai-architecture, #embodied-ai, #robbyant-lingbot-2.0, #world-models-in-robotics, #robot-perception-and-action, #good-company, and more.
This story was written by: @jonstojanjournalist. Learn more about this writer by checking @jonstojanjournalist's about page, and for more stories, please visit hackernoon.com.
Robbyant’s LingBot 2.0 takes a full-stack approach to embodied AI, designing intelligence around the demands of physical environments rather than adapting systems built for language or entertainment. Its six models cover perception, spatial understanding, world modeling, prediction, and execution. By connecting these capabilities and training across 20 robot configurations from 17 brands, the architecture aims to support intelligent behavior across different robot bodies and real-world settings.
You May Also Like
TechCrunch Daily Crunch
TechCrunch
Bitcoin Audible
Guy Swann
AI Fire Daily
AIFire.co
Chat GPT Podcast
Sol Good Network
Chat GPT Infinite Intelligence
Sol Good Network

Open Source Archives - Software Engineering Daily
Software Engineering Daily
Theo - t3․gg
Theo - t3․gg
Radio Miraya
Radio Miraya

Jack Hopkins
Jack Hopkins
Learn Cardano Podcast
Pete Bui
TechCrunch Daily Crunch
TechCrunch
Bitcoin Audible
Guy Swann
AI Fire Daily
AIFire.co
Chat GPT Podcast
Sol Good Network
Chat GPT Infinite Intelligence
Sol Good Network
Open Source Archives - Software Engineering Daily
Software Engineering Daily
Theo - t3․gg
Theo - t3․gg
Radio Miraya
Radio Miraya
Jack Hopkins
Jack Hopkins
Learn Cardano Podcast
Pete Bui
Community discussion